About Me
Hello! I’m Aswath Muthuselvam, a software engineer at Magic Leap, where I work on ground-truth data using advanced camera systems and motion-capture systems for applications like hand tracking, localization and mapping.
I graduated from the University of Maryland, College Park, with a Master of Engineering in Robotics, and worked with Prof. Dinesh Manocha at the GAMMA lab. Before that, I earned a Bachelor’s in Electronics and Communication Engineering from Vellore Institute of Technology, and interned at Ericsson India Global Services on deep-learning-based disease detection in horticultural crops.
Companies & Teams
- Magic Leap
- GoogleXR · Syntec · DeepMind
- Ericsson
Publications
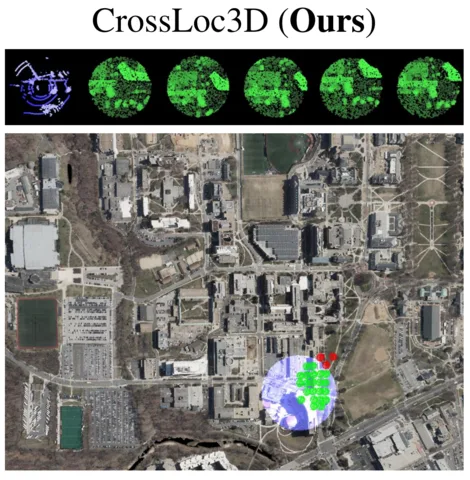
CrossLoc3D: Aerial-Ground Cross-Source 3D Place Recognition
ICCV 2023
Project Page / GitHub / arXiv / Poster / Video
First, we present a cross-source point cloud dataset, which consists of ground-truth global point clouds in UTM coordinates generated from an aerial map, and query point clouds captured from Spot and Husky robots. Second, we show a novel architecture to localize the query point cloud in the ground-truth point cloud.
Advanced Machine Learning Framework for Efficient Plant Disease Prediction
5th Asia Conference on Machine Learning and Computing (ACMLC 2022), IEEE
A smart-agriculture platform where farmers get help with plant diseases from the community. Deep learning identifies the disease from a photo of the affected plant, NLP ranks the solutions posted by the community on a Twitter-based message channel, and a concept-drift approach adapts the recommended solution to changing conditions.
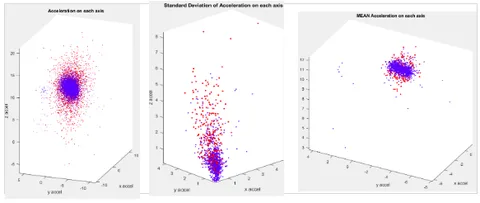
Real-Time Pothole Detection with Onboard Sensors and Camera on Vehicles
Lecture Notes in Electrical Engineering (LNEE), vol. 792, Springer, 2022
Detecting potholes in real time with a vehicle’s onboard sensors and camera, so the data can be used to manage road repairs at scale. An SVM classifier reached 98.1% accuracy on data collected over about 2 km of local road with 26 potholes.
Selected Projects
Self-Driving Car Trajectory Prediction
Predict the trajectory of a self-driving vehicle, given a bird’s-eye view of the traffic scene. Used Lyft’s prediction dataset and the L5Kit Jupyter notebook templates, combining the attention mechanism of a Vision Transformer with a fully connected layer to predict the trajectory.
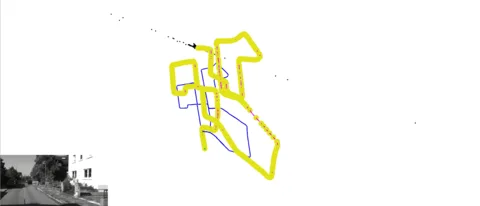
Monocular Visual Odometry
- Build the camera trajectory from a continuous image stream (KITTI Vision dataset).
- Plot the trajectory and the triangulated 3D feature points in a map for visualization (Pangolin viewer).
Human Pose Estimation and Forecasting
- Improved accuracy over the SOTA PoseFormer architecture by using various loss functions for human pose estimation.
- DA-STS-GCN (Domain Adaptive Space-Time-Separable Graph Convolutional Network) for human pose forecasting.
- Trained the networks on the Human3.6M dataset.
Omnidirectional Robot with UR5 Arm
A 6-DOF arm can manipulate objects in SE(3) (translation + rotation), but one constraint remains: the arm’s reachability. Omnidirectional wheeled mobile robots can move in any direction in the XY plane, allowing more freedom than non-holonomic car-like robots. Combining the two gives a high-DOF arm with unlimited reach in the XY plane, useful for warehouse operations and agricultural tasks.
Technical approach
- Arm: inverse kinematics using the pseudo-inverse Jacobian.
- Base: wheel angular velocities by inverting the forward transformation from the base frame to the wheel frames, with PID feedback control on position error.
Ground-Plane Free-Space Segmentation for Autonomous Robots
Using a 128×128 RGB image to predict the free space on the ground for a wheeled mobile robot navigating its environment.
- Neural network: a small U-Net trained on a custom dataset, with an inference time of 7 ms.
- Classical vision (2 ms, shown in the video):
- Sample points near the robot and segment the image.
- Track the points across frames with optical flow and compute a homography.
- Filter out points that do not follow the homography of the points closest to the robot.
- Remove segments with a low density of points.